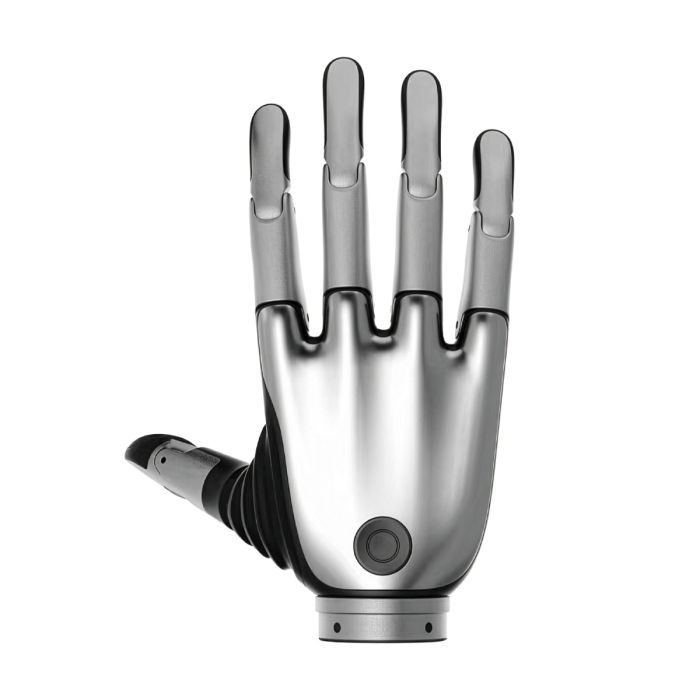
BrainCo Revo 2 Pro Dexterous Right Hand (XER)
In stock
- BRAND:
- BRAINCO
- MODEL:
- REVO 2 PRO
- PART #:
- XER
- ORIGIN:
- China
- Warranty:
- 12 MONTHS
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- BrainCo-Revo-2-Pro
BrainCo Revo 2 Pro Dexterous Right Hand (XER)
Ask an engineer what makes a robot hand look human and the answer is usually the thumb. It is also where many designs give up. The BrainCo Revo 2 Pro Dexterous Right Hand (XER) gives the thumb two active degrees of freedom and builds the rest of the hand around that decision: a bionic hand for robot integration and research, in the Pro version and the right-hand form.
The product is available through this page, by quotation.
Background
BrainCo and the Revo 2 family
BrainCo makes the Revo range of bionic hands, and the Revo 2 is its second generation. The family comes in three versions: Basic (XRL/XRR), Pro (XEL/XER) and Touch (XTL/XTR). Each version exists as a left hand and a right hand, and the final letter of the code tells them apart. This page covers the Pro right hand, XER.
The family belongs to the wider category of robot hands, which are fitted to humanoid platforms and to manipulation research benches. Teams that compare several hands usually start from the family page, BrainCo Revo 2, and from the overview of Hands, and then narrow the choice by version and by side.
Where the Pro version sits
The Revo 2 Pro is the version that sits between the entry trim and the tactile model. The second-generation advanced version and the tactile version both support three communication interfaces: RS485, CAN FD and EtherCAT, with the interface located below the wrist. For an integrator this matters more than it first appears, because the control bus often decides which hand can be used on a given robot.
Across the whole series the hand provides 6 active joints and 11 degrees of freedom. It has closed-loop servo control, custom gesture definitions, and protections for current, stall, high temperature and collision conditions. The SDK supports Linux, Windows and ROS workflows, so the hand can be driven from the environments in which research software is normally written.
Technical Specifications
| Specification | Value |
|---|---|
| Product type | Bionic dexterous hand for robot integration and research |
| Version code | XER (Pro, right hand; XEL is the left hand) |
| Active joints | 6 |
| Degrees of freedom | 11 |
| Thumb | Two active degrees of freedom for abduction and adduction; one passive degree of freedom for flexion and extension |
| Other four fingers | Each has one active and one passive degree of freedom for flexion and extension |
| Communication interfaces | RS485, CAN FD, EtherCAT |
| Interface location | Below the wrist |
| Control | Closed-loop servo control; custom gesture definitions |
| Protections | Current, stall, high temperature and collision |
| SDK | Linux, Windows and ROS workflows |
Specifications as published by the manufacturer; confirmed against the datasheet at quotation.
The manufacturer has not published the dimensions, the wrist mounting dimensions, the material, the IP rating or the service life; they are confirmed at quotation.
What does the Pro version add over the Basic version?
The clearest difference is the communication offer. The Pro version supports RS485, CAN FD and EtherCAT, and the interface sits below the wrist. A team that runs an EtherCAT master, or that wants to move between buses as a project matures, can then keep the same hand throughout. The hand does not have to be replaced when the controller architecture changes.
The joint layout, the control features and the SDK support apply to the whole series, so they are not a reason to choose Pro over another version. If your robot does not need the Pro interface set, the BrainCo Revo 2 Basic Right Dexterous Bionic Hand (XRR) is the sibling to compare. Ask for its interface set when you send your request.
How does the Pro version differ from the Touch version?
On the communication side, Pro and Touch are comparable, since both support the three interfaces. The Touch version is the tactile model of the family, so it is the one to consider if your experiments depend on contact sensing. The right-hand Touch model is the Brainco Revo 2 Touch Biomimetic Dexterous Right Hand (XTR). Ask us for its sensing details when you send your request.
Who is the BrainCo Revo 2 Pro Dexterous Right Hand (XER) for?
Research laboratories are the first segment. A hand with 11 degrees of freedom, custom gesture definitions and an SDK for Linux, Windows and ROS suits groups that write their own manipulation and grasping software and need to change the control strategy between experiments.
Humanoid and mobile manipulation developers are the second. They need a hand that connects over the bus their platform already uses, and that protects itself against current, stall, high temperature and collision conditions when a trial goes wrong. Integrators building demonstration or pilot cells are the third, since the interface below the wrist keeps the connection point in a predictable place.
This page is for the right hand. A bimanual robot also needs the left-hand counterpart, the BrainCo Revo 2 Pro Dexterous Left Hand (XEL), so that both hands share the same version and the same interfaces.
What is the BrainCo Revo 2 Pro Dexterous Right Hand (XER) used for?
- Robot integration: fitting a bionic hand to a humanoid or manipulator arm and connecting it over RS485, CAN FD or EtherCAT.
- Manipulation research: testing grasp strategies on a hand with a thumb that has two active degrees of freedom.
- Gesture programming: defining custom gestures and calling them from the control software.
- ROS-based development: building and testing behaviours inside ROS workflows supported by the SDK.
- Bimanual experiments: pairing the right hand with the left-hand Pro version for two-handed tasks.
- Protection testing: running trials in which current, stall, high temperature and collision protections limit the risk to the hand.
Pricing and Availability
Pricing is provided by quotation, and this page is where a request starts. Delivery, customs and support are arranged together with the quotation. Tell us the robot platform, the control bus and the quantity you need, and we will respond with the details for the Pro right hand. The BrainCo Revo 2 Pro Dexterous Right Hand (XER) is available on this page.
Frequently Asked Questions
What does the XER code mean?
XER is the version code of the Pro right hand. The Pro left hand is XEL.
How many joints and degrees of freedom does the hand have?
It has 6 active joints and 11 degrees of freedom. The thumb has two active degrees of freedom and one passive degree of freedom, and each of the other four fingers has one active and one passive degree of freedom.
Which communication interfaces does the Pro version support?
It supports RS485, CAN FD and EtherCAT. The interface is located below the wrist.
Which operating systems does the SDK support?
The SDK supports Linux, Windows and ROS workflows.
What protections does the hand include?
It includes protections for current, stall, high temperature and collision conditions, together with closed-loop servo control.
How do I obtain the dimensions and the IP rating?
Include them in your quotation request and our team will answer with the quotation.
Where can I buy the BrainCo Revo 2 Pro Dexterous Right Hand (XER) and what does it cost?
It is available through this page, by quotation. No price is shown here; send a request and the quotation will set out the terms, including delivery, customs and support.
Summary
The thumb is where a robot hand either earns its place or loses it, and the Revo 2 Pro builds on a thumb with two active degrees of freedom. Around it are 6 active joints, 11 degrees of freedom, three communication interfaces, closed-loop control and a set of protections, which together make it a hand meant to be integrated and not only admired. Choose the Pro version when the control bus matters, and pair it with the left-hand model for bimanual work. For the BrainCo Revo 2 Pro Dexterous Right Hand (XER), this page is the starting point.
Specifications
General
Physical
Mobility
Performance
Connectivity
Software
Hand
Feature
1. High quality and stability – five years of product iteration and professional production lines.
2. Lightweight (383 grams), with 5 kg active grip force, 20 kg single-hand load capacity, and a grip-to-weight ratio of 53.
3. Ergonomic Bionic Design – supports curved surface grasping with anti- collision finger design.
4. Multi-dimensional tactile perception – pressure, friction, direction, proximity, and surface texture.
5. High Sensitivity Tactile Perception – max resolution of 0.01N.
6. Wide voltage support – 64V.
7. Universal Interfaces – RS485 & CAN-FD, and EtherCAT.
8. Standard Protocols and SDKs – Modbus & Protobuf protocols, SDKs for Python / C / ROS.