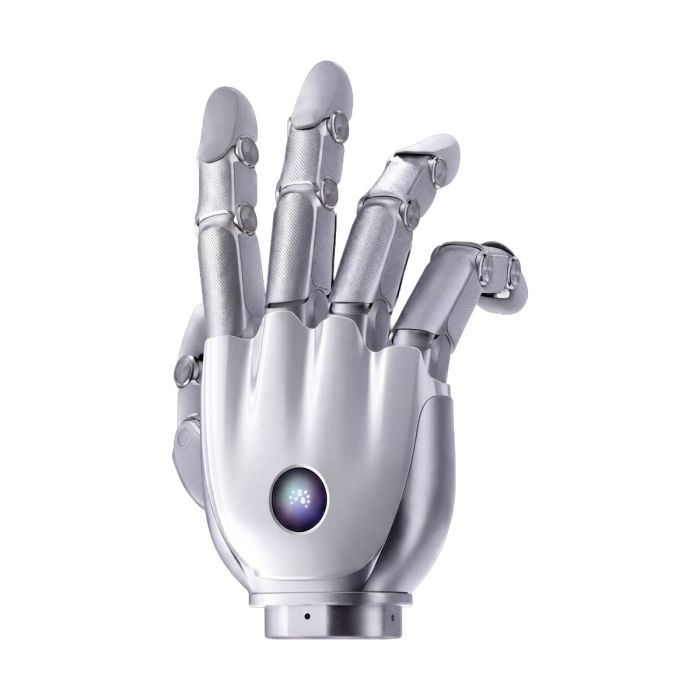
BrainCo Revo 3-21 Basic Robot Hand
In stock
- BRAND:
- BRAINCO
- MODEL:
- REVO 3-21 BASIC
- ORIGIN:
- China
- Warranty:
- 12 MONTHS
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- BrainCo-Revo-3
BrainCo Revo 3-21 Basic Robot Hand
A robot arm can be precise to the millimetre and still be let down by what it holds at the end. The BrainCo Revo 3-21 Basic Robot Hand is aimed at that last link: a biomimetic hand with 21 independently driven motors, for teams that want to command each finger rather than simply close a clamp.
The product is available through this page, by quotation.
Background
BrainCo and the Revo lineage
BrainCo was founded in 2015 and already offers three robotic products. Within that range, the Revo name belongs to its dexterous hands, and the Revo 3 family is presented in several versions: Revo 3 U21, U21F, U21T and U21VT in the manufacturer's table, and Basic, Touch and Vision in the naming used by sellers. Earlier hands in the line, such as the Revo 1 and Revo 2, sit alongside it in the catalogue for buyers who need a simpler or more established option.
Positioning and key technology
The Revo 3 is a biomimetic dexterous hand designed for industrial automation, scientific research and advanced robotics manipulation. Its architecture rests on 21 fully active, independently driven degrees of freedom: five in the thumb and four in each of the index, middle, ring and pinky fingers. The joints are direct-driven and backdrivable, which provides rapid response and high control density across all finger segments. The hand is rated for over 1,000,000 joint flex cycles, and cross-platform C/C++ and Python SDKs for Linux and Windows support integration work. The wider range is listed under BrainCo Revo 3.
Technical Specifications
| Specification | Value |
|---|---|
| Degrees of freedom | 21, fully active and independently driven |
| Drive type | Direct-driven, backdrivable joints |
| Hand dimensions | 216 × 108 × 50 mm |
| Supply voltage | 16–85 V |
| Max current | 10 A (24 V) |
| Max active grip force | ≥100 N |
| Max fingertip pinch force | ≥25 N |
| Total hand payload | 20 kg |
| Four-finger payload | 5 kg |
| Repeatability | 0.1° |
| Joint open/close time | 0.33 s |
| Max grasping diameter | 150 mm |
| Communication interfaces | EtherCAT / CAN FD / RS-485 |
| Communication frequency | 500 Hz |
| Onboard sensors | IMU (mainboard), temperature (mainboard) |
| Tactile sensors (Basic) | Not included |
| Control modes (Basic) | Position / MIT Force-Position / Admittance / Zero-Torque |
| Reliability | Over 1,000,000 joint flex cycles |
Specifications as published by the manufacturer; confirmed against the datasheet at quotation.
The manufacturer has not published the weight, the box contents, the IP rating, the operating temperature range or the power consumption; they are confirmed at quotation.
What makes the Basic version different from the Touch versions?
The Basic version does not include tactile sensors. Its feedback comes from the mainboard, which carries an IMU and a temperature sensor, so the hand suits work in which finger position and motor control matter more than contact sensing at the fingertip. This keeps the configuration focused on motion.
Buyers who need contact feedback should look at the BrainCo Revo 3-21 Touch Robot Hand or the BrainCo Revo 3-21 V-Touch Robot Hand. The fact sheet lists the hand dimensions of the manufacturer's table as the same for all four U21 models.
How does the Revo 3 control its fingers?
Each of the 21 degrees of freedom has its own motor, so the controller addresses the thumb and fingers joint by joint. Because the joints are backdrivable, an external push on a finger can be followed by the mechanism instead of being resisted. The Basic version lists four control modes: position, MIT force-position, admittance and zero-torque. Communication runs over EtherCAT, CAN FD or RS-485, at a communication frequency of 500 Hz.
Who is the BrainCo Revo 3-21 Basic Robot Hand for?
Research laboratories are the clearest segment: a 21-DoF hand with C/C++ and Python SDKs gives groups a platform for studying grasping and in-hand manipulation. Robot integrators building humanoid or arm-mounted systems will value the three communication interfaces and the payload figures. Industrial automation teams that handle varied parts can use the individual finger control where a two-jaw gripper falls short.
Teams that need fingertip contact sensing should consider the Touch version instead. Those with a simpler requirement may compare the earlier Revo 2 Basic Right Dexterous Bionic Hand.
What is the BrainCo Revo 3-21 Basic Robot Hand used for?
- Dexterous manipulation research: studying grasp planning and finger-level control on a 21-DoF hand.
- Humanoid robot end effector: giving a humanoid platform a hand with a human-like finger layout.
- Industrial handling: picking varied parts where a fixed gripper cannot adapt.
- Teleoperation and demonstration: following an operator's finger movements through the control modes.
- Compliant interaction: using backdrivable joints and admittance control for gentle contact.
- Algorithm development: building controllers with the Python and C/C++ SDKs on Linux or Windows.
Pricing and Availability
No price is shown on this page; a quotation is the way to proceed. Delivery, customs and support are arranged with the quotation. The BrainCo Revo 3-21 Basic Robot Hand is available on this page.
Frequently Asked Questions
How many degrees of freedom does the hand have?
It has 21 fully active, independently driven degrees of freedom: five in the thumb and four in each of the other four fingers.
Which communication interfaces are supported?
The manufacturer's table lists EtherCAT, CAN FD and RS-485, with a communication frequency of 500 Hz.
Does the Basic version include tactile sensors?
No. Tactile sensors are not included; the onboard sensors are an IMU and a temperature sensor on the mainboard.
What software is available?
Cross-platform C/C++ and Python SDKs are available for Linux and Windows.
What payload can the hand carry?
The manufacturer's table gives a total hand payload of 20 kg and a four-finger payload of 5 kg.
Is the IP rating published?
No. The IP rating, along with the weight and operating temperature range, is confirmed at quotation.
Where can I buy the BrainCo Revo 3-21 Basic Robot Hand and what does it cost?
It is available through this page by quotation. Pricing is provided with the quotation, together with delivery and support arrangements.
Summary
The end of a robot arm is where most of the work is decided, and the BrainCo Revo 3-21 Basic Robot Hand gives that point 21 independently driven joints, backdrivable motion and open SDKs. It omits tactile sensing by design, which keeps it focused on motion control. For a quotation, this page is the starting point.